SLAM Navigation For An Arduino Powered Automobile
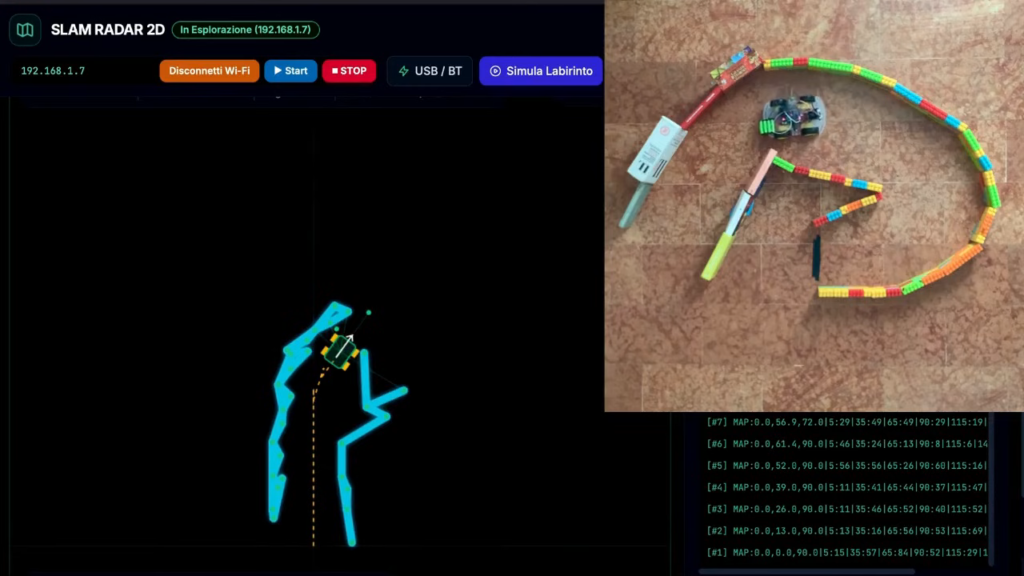
There are loads of “robotic” tasks on the market which are actually only a small distant management platform of some type. We typically like to think about robots of getting some kind of autonomy although. [Luca Fagioli] demonstrates a fantastic instance of this along with his explorer robotic that uses Simultaneous Localization and Mapping (SLAM) to navigate its environment.
The robotic is a constructed on a small plastic chassis, with one gear motor per drive wheel. Running the present is an Arduino Uno R4 Wi-Fi, paired with the Sensor Shield 5.0 and an L298N motor driver board. There’s additionally an HC-SR04 ultrasonic sensor module onboard, mounted atop an SG-90 servo motor so it may be panned round. The ultrasonic sensor determines the vary between the robotic and surrounding partitions, and a map is constructed similtaneously the robotic is localizing itself inside it. There are additionally infrared sensors on the underside of the robotic for detecting tape marks on the ground for checkpointing functions.
Often, SLAM mapping is completed with advanced laser rangefinders or time of flight sensors, however there are various methods to go about it as this undertaking demonstrates. We’ve even seen it carried out in a distributed manner with coordinated drones combining their efforts. Overall, it’s a extremely helpful approach for robotic navigation and wayfinding.