An Open Micro-Maniplulator Improved | Hackaday
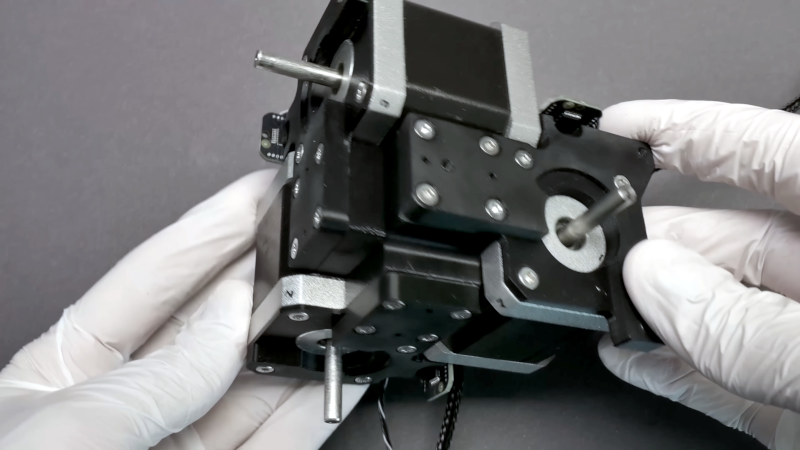
If you want a micro-manipulator, you in all probability have already got a good suggestion of what it does. For instance, you may be transferring a probe over an IC die or wafer. You may be one thing by way of a microscope. The key’s transferring one thing in very small, exact increments alongside three axes. An open-source design for a micro-manipulator has seen vital enhancements recently. You can see a number of movies in regards to the system under.
The system makes use of stepper motors, parallel kinematics, and miniature ball joints to attain exact movement. The current model 4.0 replace fixes a couple of issues. According to the GitHub web page:
- Self-collision throughout homing fastened.
- Connection of the ball joint block with screws solely was not properly constrained and may very well be rotated a bit.
- No dependable means to make sure constant linkage rod size
- Unnecessary ball joint friction
- Accurate ball place closely depending on print high quality and nook rounding
- Rubber bands couldn’t be modified or eliminated as soon as glued in.
We’ve lined earlier versions of this device, and we have been watching the improvements to the ball joints. Since then, the undertaking has up to date a lot of its mechanical design and documentation, and it has additionally modified the API that drives it. It may even use instruments in g-code now to help issues like positive management over laser engraving.
If you favor one thing old-school guide, contemplate a 3D-printed one.