Instructing A Robotic Hand To Stroll
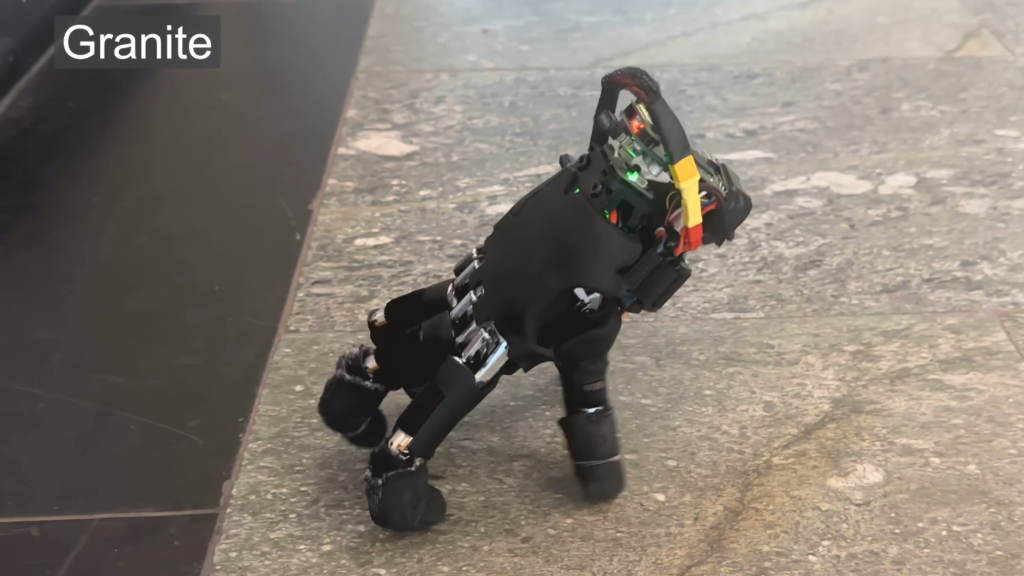

Although it wasn’t apparently designed with this in thoughts, it appears notably fortuitous that this walking robotic hand was launched in time for Halloween. Designed by researchers from ETH Zurich, the marginally unsettling disembodied hand can use its fingers as legs to traverse terrain, push small objects round, and function a keyboard.
The researchers began from commercially-available robotic hand, outfitted it with a battery and Raspberry Pi Zero 2 W, and developed neural net-based software program to manage it. The hand has twenty joints, 4 per finger, and the neural internet iteratively outputs the following joint state, primarily based on earlier actions, the state of the hand, and the hand’s present objective. To practice the online, the researchers constructed a simulated mannequin, then used this for reinforcement studying; this yielded a sooner strolling pace than an tailored quadrupedal movement mannequin did.
The hand was educated to maneuver in a straight line, flip, get well from a fall, and press the keys of a keyboard (because it doesn’t have a digital camera, although, it may’t function a keyboard by itself). The fall restoration is spectacular to observe: in 21 out of 25 exams, it was in a position to proper itself inside twenty seconds. Due to the hand’s geometry, it drifts to the precise whereas strolling, so a continuing correction wanted to be utilized. It did, nonetheless, handle to efficiently cross fourteen various surfaces, ranging in roughness from a rubber mat to gravel and grass. It even managed to push mild objects towards objectives.
The authors envision this sort of autonomous hand enabling larger freedom for a bigger robotic, resembling a robotic arm: if it wants to achieve one thing farther away, the hand merely detaches and walks over. Regardless of the use to which they put in, such a undertaking is already inside attain of hackers; we’ve seen a couple of robotic hand tasks right here over time.